Category
Journey Notes
Field notes and project journals: UAV cargo delivery, an autonomous underwater welding ROV, and the lessons that came out of building them.
The work that happens away from the CAD desk: a seminar and delivery-network proposal from a UAV team, a conference paper on an autonomous underwater welding and inspection ROV, and the question of where to cut module boundaries in a codebase that keeps growing.
The UAV article walks through the real cost lines of parcel logistics and a delivery network built on mobile ground control stations. The ROV article summarises a design that puts underwater welding and weld inspection into one vehicle, supported by image processing and machine learning. The modular architecture article argues for cutting boundaries by rate of change rather than by technology, and covers how to version data contracts and what decision records are actually for.
These are project journals rather than tutorials: what was attempted, what did not hold, and what was left standing after the decision. Written for readers who want to see mechanical design, embedded systems and software architecture collide inside one project.
For the same engineering approach in productised form, see the case studies under Projects; for its CAD-side counterpart, see the CAD Automation category.
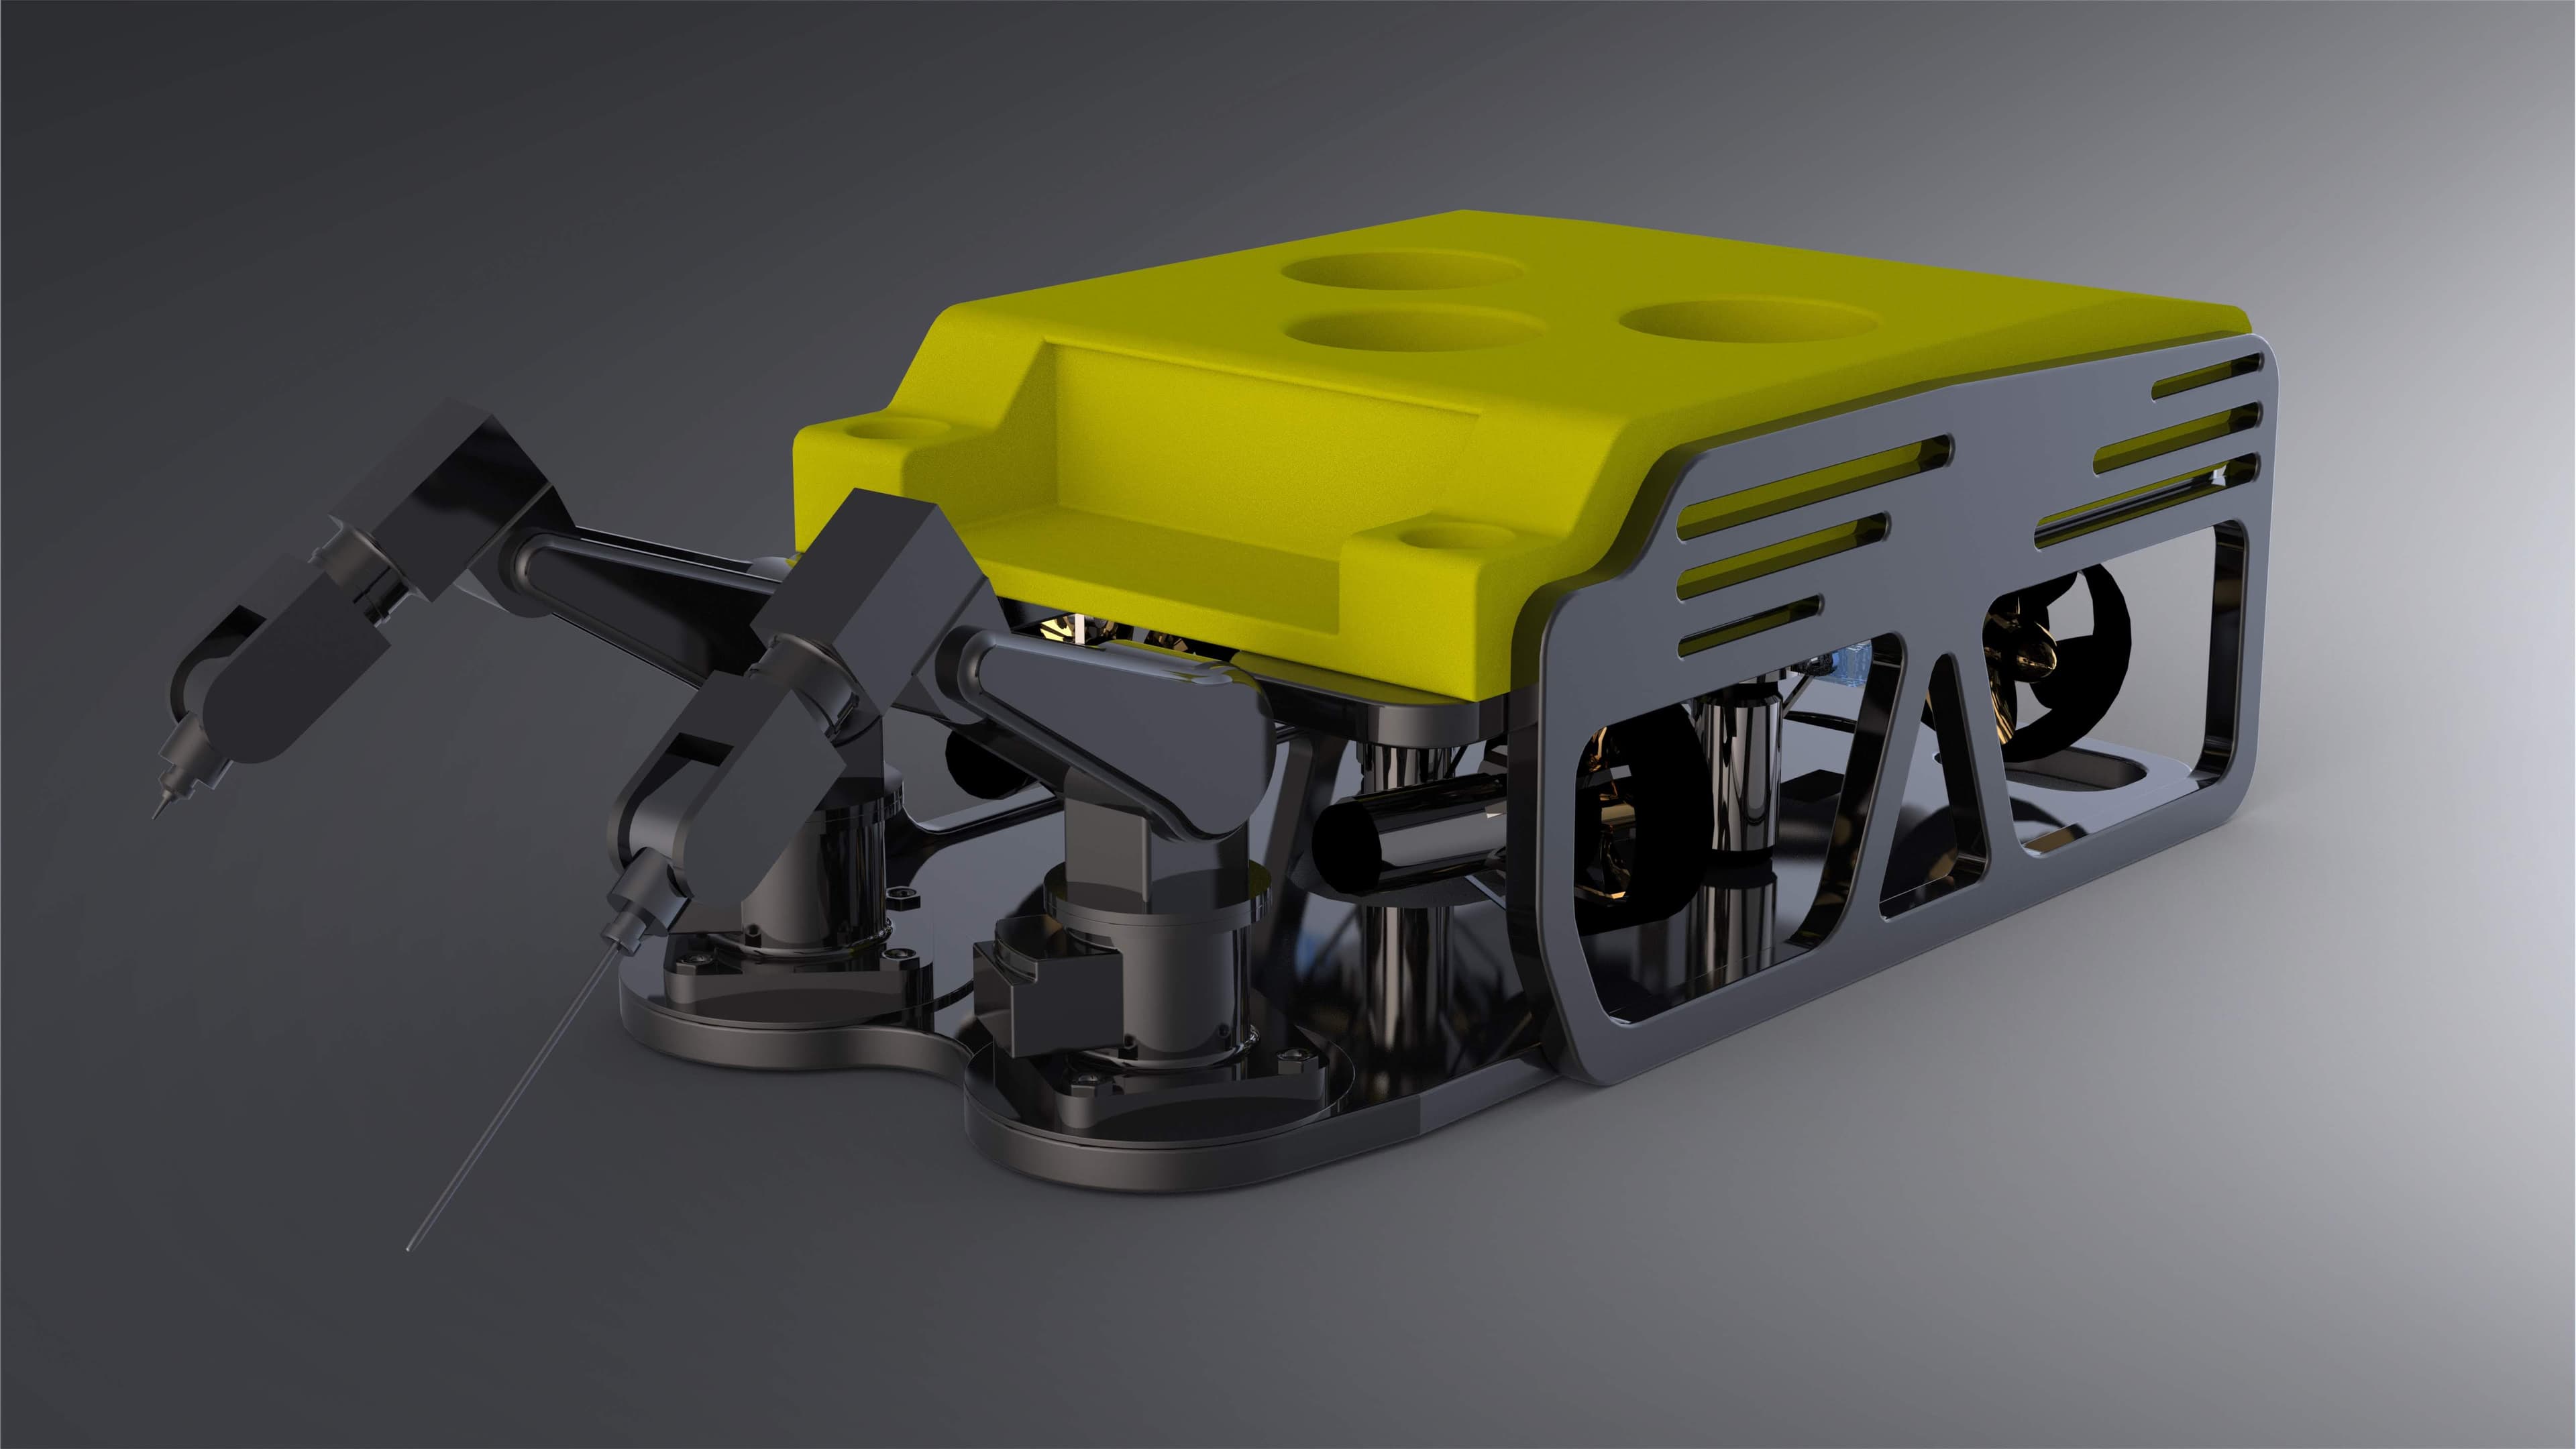
Autonomous Underwater Welding and Inspection ROV — DYUK'22
The ROV from our DYUK'22 paper: underwater welding and weld inspection in one autonomous vehicle, using image processing and machine learning. Paper ID 4449.
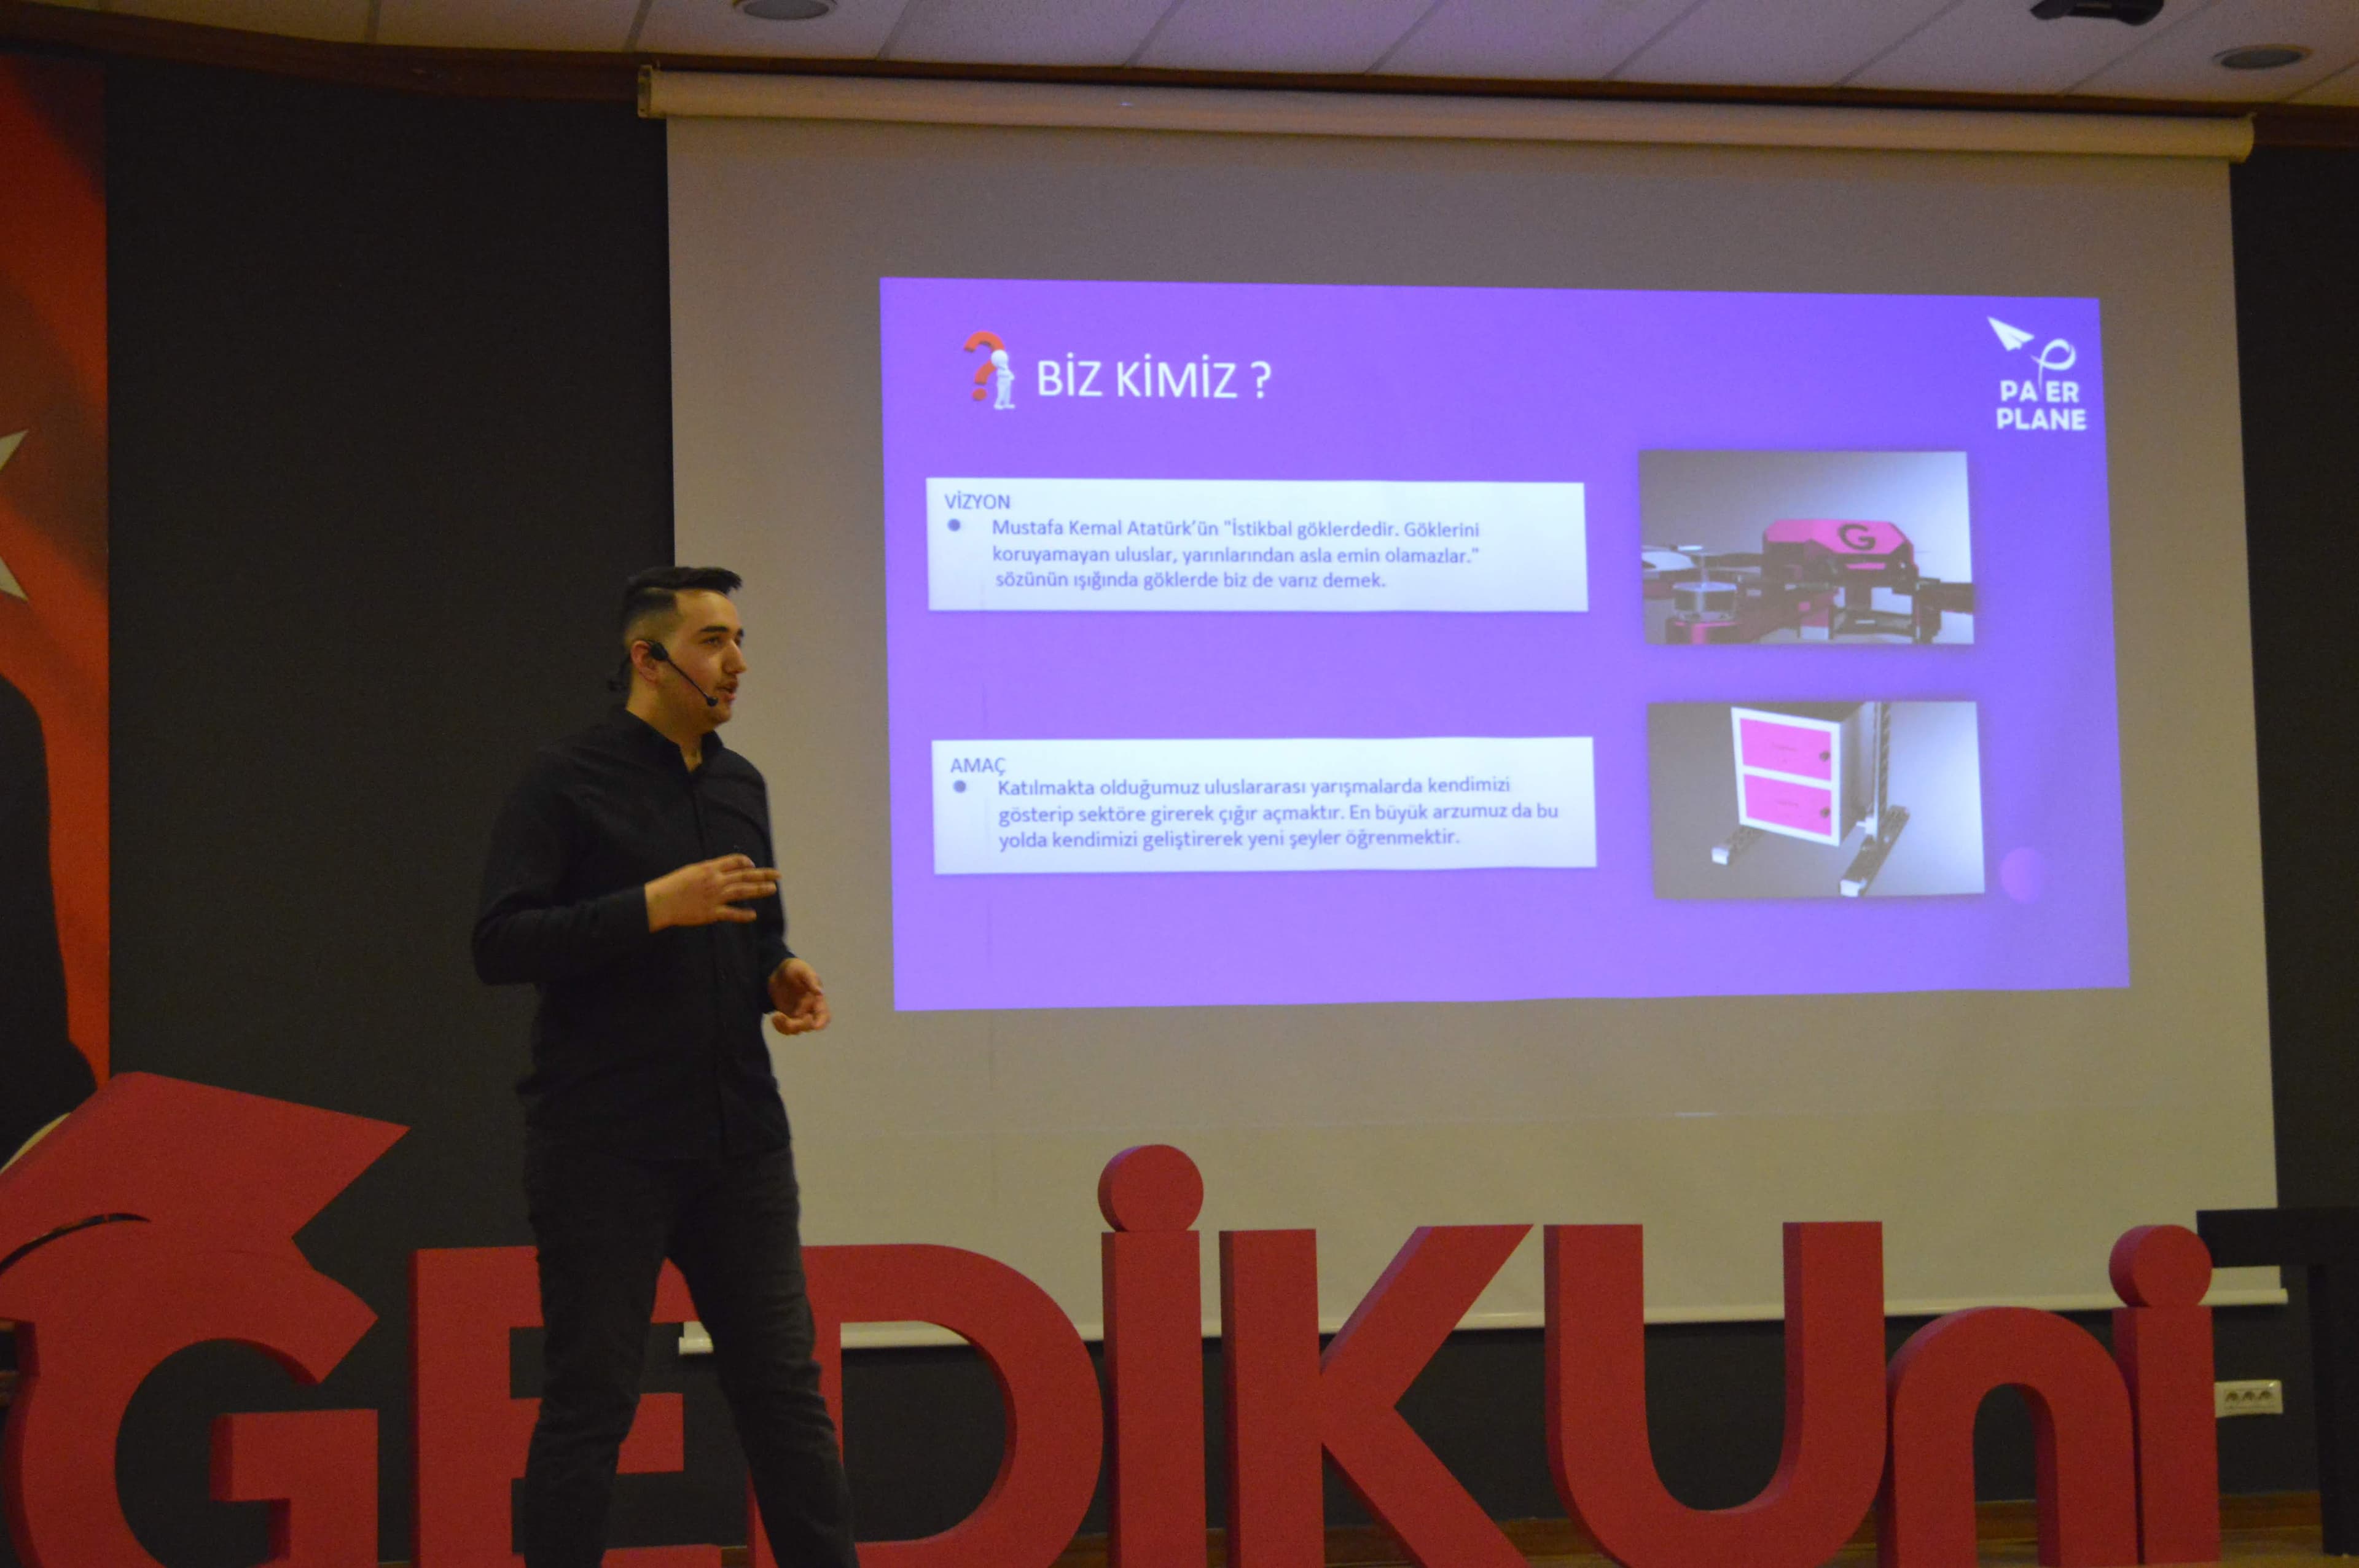
Cargo Delivery by UAV: Founding the Paper Plane Team
The UAV seminar I gave at Gedik University: the real cost lines of parcel delivery, a network of mobile ground control stations, and the Paper Plane airframe.

Modular Software Architecture for CAD/CAM and Automation
Modular architecture for engineering software: cut modules by rate of change, not by technology. Module groups, data contracts, decision records and tests.